

Technical specifications and
performance of DynaKite®
An automated kite to tow a vessel?
Yes, it’s possible!
DynaKite® is an automated kite traction solution. Using a kite wing controlled by an autopilot, the DynaPod, it assists the propulsion of vessels over 12 meters.
DynaKite®: the alliance of wind,
mechanics and embedded intelligence
Here is the overview of the DynaKite® system. Discover each component through this interactive section.
Hybrid kite wing with an aerodynamic arched shape, for enhanced stability and performance.
- Bridle-free: no adjustment needed, even during launch and recovery
- Self-inflating: automatically inflated by the wind during launch
Only two lines connect the kite to the DynaPod autopilot, with a length between 70 and 140 meters depending on the DynaKite® power used. These lines allow you to:
- Transmit the traction forces generated by the kite wing to the vessel
- Steer the kite wing
Easily installed on the vessel’s deck with just 5 bolts, the DynaPod flies the kite automatically thanks to its built-in sensors. Its mobile motorization system enables 360° loop flight.
The controller allows the operator to remotely control the system while receiving real-time feedback on its status. It also lets the operator switch between flight modes.
Offers smart control with real-time visualization of the kite’s performance for optimal control.
The major innovation that sets this system apart from our other two solutions: the 360° loop flight mode, which generates continuous traction. This perpetual motion guarantees a stable and powerful force, with no risk of line tangling. This technical feat is made possible by the DynaPod, equipped with a wheel motor and a swivel.
Loop flight is widely recognized as the most effective trajectory for maximizing a kite’s power. Academic research has demonstrated this for many years, and the world’s top kitesurfers rely on it every day. With DynaKite®, we have developed a unique mechanism that fully harnesses this optimal flight path through a swivel integrated beneath the wheel drive unit.
How does the kite
generate traction?
The aerodynamic profile of our kite wings relies on a key physical principle. Air accelerates over the upper surface*, creating a low-pressure zone, and slows down beneath the lower surface**, creating a high-pressure zone. This pressure difference produces lift, the force that tows the vessel.
*upper surface: the top side of the wing
**lower surface: the underside of the wing
The different flight modes
For launch, the operator uses the controller and controls the line unrolling speed. At the end of the unrolling, the redirection systems are released and the pulleys are removed from the lines.
For recovery, from the control unit, the operator manually selects recovery mode, then controls the line winding speed with a simple joystick.
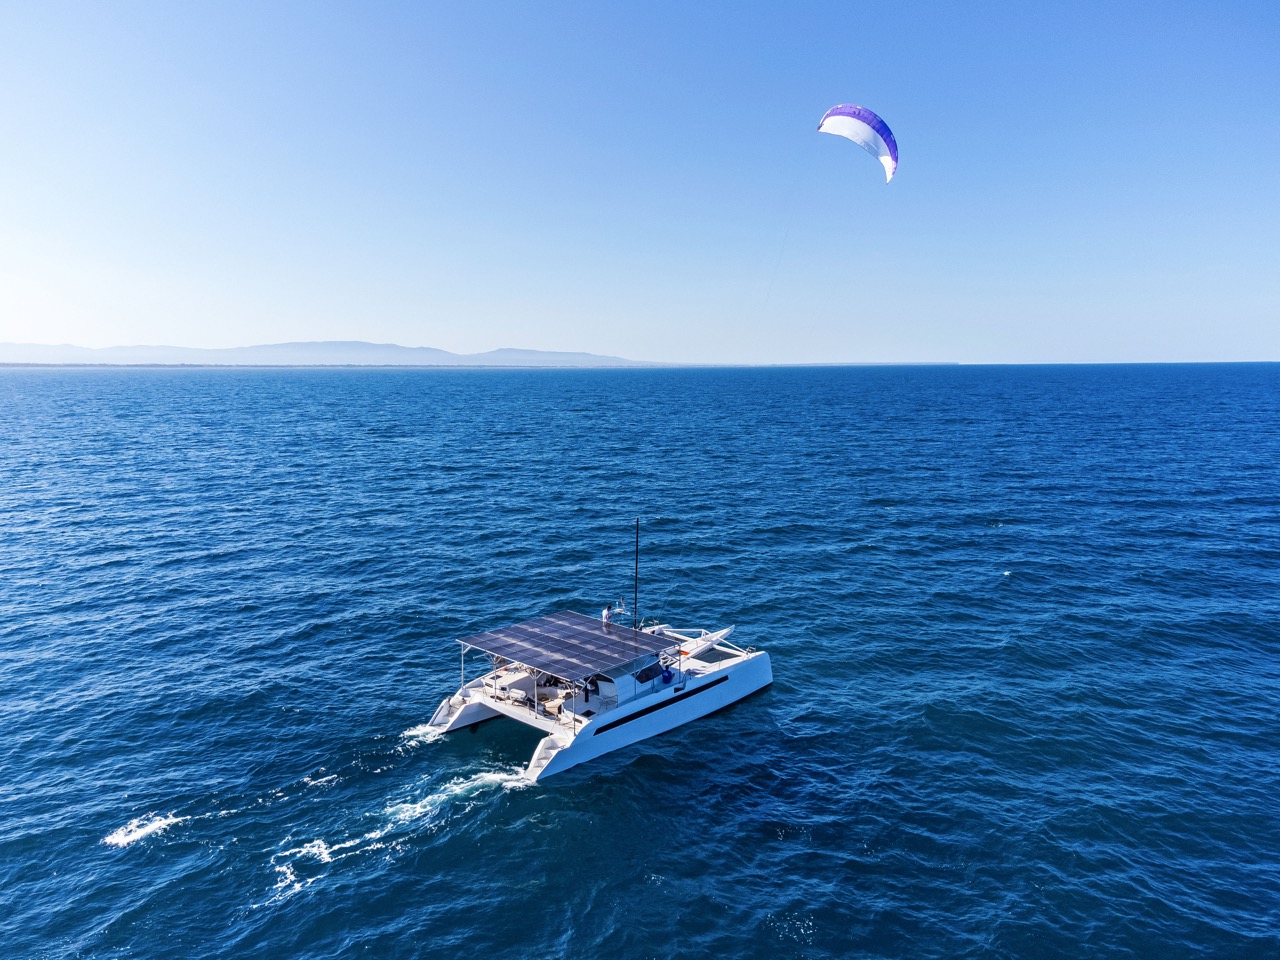
Static mode is ideal for optimizing traction when sailing close-hauled. The autopilot holds the kite in a stable position at the edge of the window, generating optimized traction along the vessel’s direction of travel.
A variant of this mode, called “Zenith,” keeps the wing at the top of the flight window to limit traction during maneuvers.
Dynamic modes optimize the kite wing’s movement within the wind window thanks to the DynaPod:
- 360° loop flight: the kite rotates continuously within the wind window, generating maximum, continuous traction.
- Figure-eight flight: the kite traces figure eights within the wind window.
Dynamic flight modes and the shape of their trajectories automatically adapt to wind angle and speed to maximize traction.
Thanks to its sensor network, the DynaPod continuously analyzes wind conditions and adapts the kite’s trajectory and flight mode. From static flight to zenith, from figure eights to 360° loops, it adjusts every movement to make the best use of wind energy and generate optimal traction.
Two power configurations available
We offer two power configurations suited to your needs: DynaKite® 60 and DynaKite® 120.